Scripting
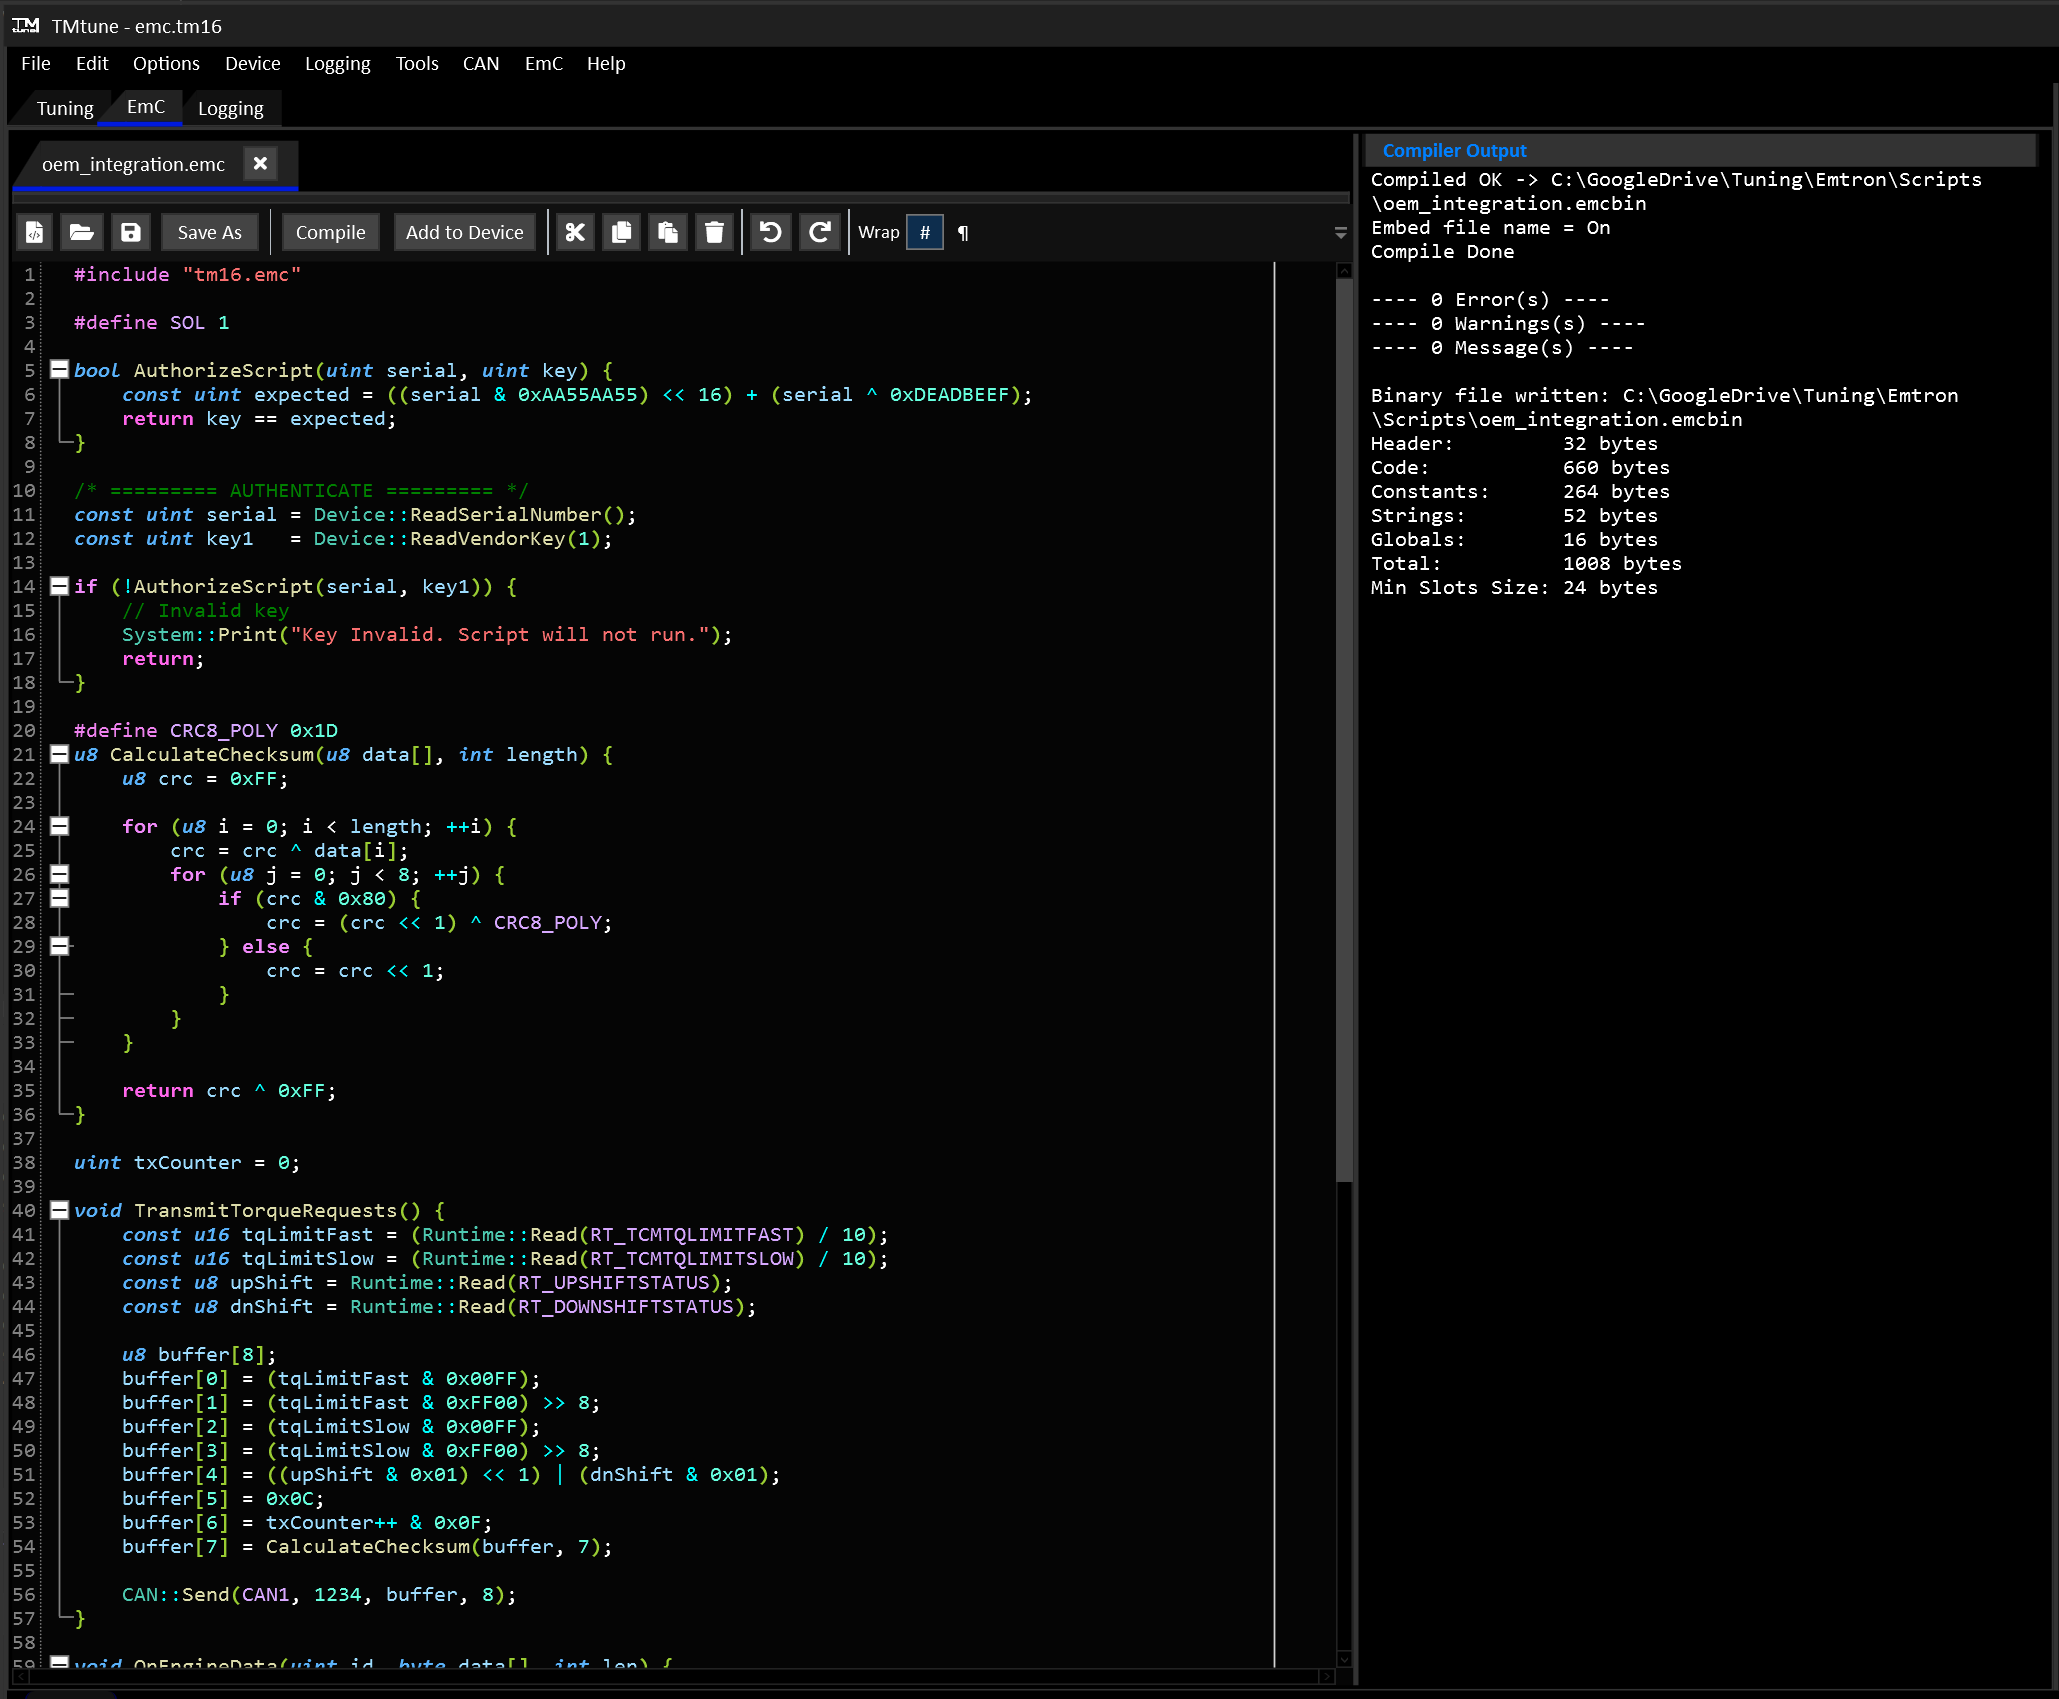
EmC is a statically-typed, heap-less, C-style scripting language for memory-constrained 32-bit embedded systems. Source files (.emc) compile to a compact bytecode binary (.emcbin) that runs on a stack-based virtual machine with no external dependencies and no runtime heap allocation.
The syntax is close to C. Most C code that avoids pointers, the heap, and the standard library will look familiar.
There is no main function. Top-level statements execute in source order when the script runs.
System:: is the namespace for functions provided by the host application, called native functions. A host can also group natives under namespaces of its own. See Native functions.
Functions and classes may be declared at the top level. They can be referenced before their declaration appears in the file (see Forward references).
EmC supports C-style single line and block comments.
EmC is a statically typed language. All data types are known at compile time, making execution faster and safer.
| Keyword | Alias | Meaning | Width |
|---|---|---|---|
void | no value (return type) | - | |
bool | true / false | 1 byte | |
char | s8 | signed 8-bit integer | 1 byte |
byte | u8 | unsigned 8-bit integer | 1 byte |
short | s16 | signed 16-bit integer | 2 byte |
ushort | u16 | unsigned 16-bit integer | 2 byte |
int | s32 | signed 32-bit integer | 4 byte |
uint | u32 | unsigned 32-bit integer | 4 byte |
float | f32 | 32-bit IEEE-754 | 4 byte |
string | immutable text constant | ref |
The alias column is just another way to declare the same keyword: s8 and char compile to exactly the same type, so they mix freely and error messages always report the char/byte/… name.
Aliases are provided for convenience as they are a little more descriptive than the classical type names.
char and byte are numeric types, not a distinct character type. Individual character literals are not supported, so an integer must be used.
string is a reference to a compile-time constant. String variables and string native parameters can only ever hold a literal or another string constant. For mutable text, use a byte array (see Strings).
null, NULL, and nil are all accepted and evaluate to integer 0.
An integer literal without a suffix is an int. Add U to make it a uint, as in C. This matters in two places: a plain literal assigned to a uint variable warns about an implicit cast, and an expression is only compiled with unsigned arithmetic and comparisons when one of its operands is unsigned, so x > 0U and x / 2U behave correctly for a uint x above 2147483647. A literal larger than 4294967295 is a compile error. An unsuffixed literal above 2147483647 keeps its bit pattern and wraps negative as an int, with a warning unless it is being assigned to a uint (so uint mask = 0xFFFFFFFF; is fine) or negated.
String literals use double quotes and must end on the line they start on. A backslash starts an escape sequence:
| Escape | Character |
|---|---|
\n | Newline (line feed) |
\r | Carriage return |
\t | Tab |
\\ | Backslash |
\" | Double quote |
\' | Single quote |
Any other escape is a compile error. That includes \0, because strings are stored null-terminated and it would cut the string short. To put a backslash in a string, write it twice: "C:\\temp". An empty string "" is allowed.
All variables are zero-initialized if no initializer is given.
{ ... }) introduce a new scope. A local is visible from its declaration to the end of its enclosing block.const marks a variable read-only after its initializer runs. Writing to it later is a compile error.
A const array must be initialized where it is declared, and its elements can’t be written after that. Assignment, compound assignment and ++/-- on an element are all compile errors. This works well for lookup tables:
A const array can only be passed to a const array parameter (see “Array Parameters”).
EmC enforces no naming convention. One common pattern is UpperCamelCase for functions and global variables and lowerCamelCase for locals and parameters, which makes a name’s scope visible at a glance and matches how the native functions are named. The compiler accepts any style, and the choice is entirely yours.
All basic mathematical and bitwise operations are supported.
Integer division and modulus by zero halt the VM with a “Division By Zero” error. Float division by zero also halts.
A comparison always produces a bool.
There is no %=, <<=, or >>=.
Both prefix and postfix forms work on a variable, a class field or an array element:
A postfix ++ or -- has to be the whole expression, as in i++; or int old = counts[b]++;. Using it inside a larger expression, such as a + i++, is a compile error. The index is evaluated once, so counts[Next()]++; calls Next() once.
Narrow types wrap at their own width:
Behaves like a single line if/else statement.
From tightest to loosest binding:
. [] () (member, index, call)! ~ ++ -- (unary)* / %+ - & | ^ << >>< > <= >=== !=&&||?: (ternary)= += -= *= /= &= |= ^= (assignment)Note that the bitwise and shift operators sit at the same level as + and -. Parenthesize when mixing them with arithmetic.
Numeric types convert implicitly across signed, unsigned, and float categories as needed by an assignment, argument, or operator. There is no explicit cast syntax.
A function call’s return value converts the same way as any other value, so float f = count(); converts an int result to float and int n = 2 * ratio(); converts a float result to int.
The compiler warns when a float is converted to an integer type, because the fractional part is lost. This covers declarations, assignments, arguments, return values and array indexes. Other conversions, such as signed to unsigned, don’t warn by default.
Mixing int and float in arithmetic gives a float, as in C. The value keeps its fraction until it is stored, passed or returned, so int n = i * f * 4; only converts to int once, at the end. When the target is a float, the whole expression is worked out in float, including integer division. So float h = i / 2; with i = 1 gives 0.5, not 0.
Bitwise operators and switch need integer values, so a mixed expression like (i + f) & 3 is a compile error.
Storing a value in a char, byte, short or ushort wraps it to that type’s range, as in C. That happens at every store: a declaration, an assignment, a compound assignment, ++/--, an argument, and a return value. Arithmetic in between is done in int, so a result is only cut down when it’s stored. This makes decoding a signed 16-bit value from two bytes work as expected:
There is no integer overflow or wraparound detection. Arithmetic that exceeds a type’s range wraps silently.
A while loop will continue as long as the condition is true.
There is no do/while.
A for loop has an initializer, condition, and update expression. The loop will continue as long as the condition is true.
All three clauses are optional. Any of them may be left empty, and for (;;) is an infinite loop.
break & continuecontinue will skip the rest of the loop body and continue to the next loop iteration.break exits the loop immediately.break and continue work in while and for loops.
The controlling expression is an integer (float is rejected). case labels are integer literals and must be unique. default is optional. A case without a break falls through to the next case, as in C.
A case with no body falls straight into the next one, which is how several values share a single handler:
A case that has a body but no break runs its own body and then continues into the next case:
switch statements are much more efficient than long if/else chains. They use a jump table to very quickly jump to the correct case label, rather than checking every entry for a match. The tradeoff is they produce more compiled binary size for large ranges.
A switch statement has to produce a jump table entry for every value between its lowest and highest case label value. This means that for large value ranges with a low number of case labels, the compiled output will be huge compared to if/else. The number of case labels has no effect on performance.
The compiler will output a warning if the number of case labels is less than half the value range.
void function must return a value.return; in top-level code ends the script early. Destructors still run for every class instance declared before it. Returning a value from top-level code is a compile error.A top-level function or class may be used before it is declared in the file. This allows mutual recursion:
An array parameter is written T name[] or T *name (equivalent). The array’s size is not part of the parameter type, so pass the length as a separate argument. A variable index used inside the function is still checked at runtime against the caller’s actual array, the same as any other array (see “Bounds checking” in the Arrays section).
Passing a non-array where an array parameter is expected, or an array of the wrong element type, is a compile error. So is giving the parameter a size (int values[4]).
Inside the function the parameter is used exactly like an array: index it, or pass it on by name to another array parameter, script or native. It cannot be used as a value on its own.
Declare an array parameter const when the function only reads it. A const parameter can’t be written inside the function, and it accepts both const and ordinary arrays. A const array can only be passed to a const parameter, since an ordinary parameter could write to it. The same applies when a function passes its own const parameter on.
See Classes.
int a[3] = {1, 2}; is a compile error.char/byte arrays pack 4 elements per 4-byte slot; short/ushort arrays pack 2 per slot. This is transparent to the script; index them normally.
A literal out-of-range index is a compile error, including a negative one:
A variable or computed index is checked at runtime instead. An out-of-range access halts the VM with an “Array Index Out Of Bounds” error rather than reading or writing whatever happens to sit next to the array:
This covers array parameters too: a function indexing a T name[] parameter with a variable index is checked against the size of whatever array the caller actually passed in, even through several levels of forwarding. It also covers an array field declared inside a class, however it’s reached: directly, through a class-typed parameter, or through a composed/embedded instance. It does not cover what a native function does with an array you pass it. See Native functions.
An array name used without an index has no value. It cannot be assigned to a scalar, returned as a scalar, or passed as a scalar argument. Pass it only to an array parameter (with a length) or index it.
String literals are immutable compile-time constants. Use them directly with the print natives:
For text you need to build or modify at runtime, use a byte buffer and the string natives. Every string native takes an explicit capacity, C snprintf-style. Nothing grows a buffer for you.
Notes and limits:
StrCopy / StrAppend take a string constant as the source, not another byte[] buffer.StrLength on an untouched buffer is 0.Classes are supported for advanced data structures.
Declared in the class body. Each instance gets its own copy.
this.field and a bare field name both refer to the current instance’s field.this.method().ClassName(params) { ... }. A class has at most one constructor. It runs when an instance is declared with an argument list:
Fields are always zero-initialized first, before the constructor body runs. A class with no constructor is declared without parentheses:
Declaring an instance of a class that has a constructor without an argument list compiles, but produces a warning.
~ClassName() { ... }. Runs automatically when the instance goes out of scope:
Pass an instance to a function or method by reference with ClassName *param. The callee can call methods on it and read or write its fields, including compound assignment.
Passing an instance of the wrong class, or a non-instance, is a compile error. A bare instance name (no ., no method call, not passed to a class parameter) has no value and cannot be used as one.
A field may itself be a class instance. The embedded instance is laid out inline in its owner and reached with a chain of .:
a.b.c.x resolves as long as each step names a class-typed field.o.inner.value += 50;.take(o.inner); where take takes Inner *i.Limits:
class A { A a; }, or A holding a B that holds an A). This is a compile error.Namespaces are optional. They group top-level declarations under a name so they can be kept tidy and referred to explicitly. They have no runtime cost or effect: a namespaced global is still a plain global, and a namespaced function is still an ordinary function.
Refer to a member from outside with the :: scope operator:
namespace Geometry { }, other members are visible without the prefix (area() can call gridSize and Point directly). Names that don’t resolve inside the namespace fall back to the global scope.namespace cannot be declared inside another namespace.System is always off limits. See Native functions.Math is reserved for the built-in math functions. See Math functions.Runs on the token stream before parsing. Two directives are supported.
Object-like macros only.
#define onward.#define SQ(x) ((x)*(x))) are a compile error.#ifdef, #if, #endif, #undef).Native functions are provided by the host application. They give a script access to the device it runs on, for example printing, timing and communications. Which natives are available depends on the host. The reference set below is a common starting point.
Every native must be called through its namespace:
A bare Yield(10) is a compile error.
Most natives are in System. A host can group others under namespaces of its own, such as CAN above.
System is always reserved.CAN::Read available, a script is still free to declare its own Read variable or function, or a Data::Read of its own.If the script calls a native the host doesn’t provide, it still compiles, but halts with a “Native Function Not Resolved” error when the call runs.
Pass an array to a native by bare name, followed by its length:
The native trusts the length you give it. Its access to the array is not bounds checked, so never pass a length larger than the array.
A native that only reads an array takes it as a const parameter, and accepts both const and ordinary arrays. Passing a const array to a native that isn’t marked const is a compile error.
Some natives take a script function as an argument, so the host can call back into the script later, for example when a CAN frame arrives. Pass the function’s bare name, with no parentheses:
A callback always returns void, and its parameters must match what the native expects. The compiler checks the parameter count, each parameter’s type, and whether it is an array, and reports a mismatch at the call site. Some natives accept any void function. A wrong parameter count is then only caught when the host calls it, which halts the script with a “Call Arg Count Error”.
An array parameter in a callback is only valid for the duration of the call. Index it or pass it on to another array parameter as usual, and copy anything you want to keep into a script array before returning.
These natives are all in the System namespace, so Print is called as System::Print("hi").
| Signature | Purpose |
|---|---|
void SetError(int code) | Signal a recoverable error code to the host. |
void Print(string str) | Write a string, no newline. |
void PrintLine(string str) | Write a string and a newline. |
void PrintInt(int i) | Write an integer and a newline. |
void PrintFloat(float f) | Write a float and a newline. |
void PrintFormat(string str, float f) | Write a format string with one float (PrintFormat("v: %f", 3.14)). |
int StrLength(const byte buf[], int capacity) | Length up to the null terminator or capacity. |
void StrCopy(byte dest[], int destCapacity, string src) | Copy a string constant into a buffer, truncating to fit. |
void StrAppend(byte dest[], int destCapacity, string src) | Append a string constant onto a buffer’s content. |
void IntToStr(byte dest[], int destCapacity, int value) | Format an integer as decimal text into a buffer. |
bool StrEquals(const byte a[], int capA, const byte b[], int capB) | Compare two buffers’ null-terminated contents. |
void PrintBuffer(const byte buf[], int capacity) | Write a buffer’s null-terminated content. |
uint NowMs() | Host uptime in milliseconds. Wraps on overflow - compare with unsigned subtraction. |
uint NowUs() | Host uptime in microseconds. Wraps on overflow, typically much sooner than NowMs. |
void Yield(uint t) | Pause for t milliseconds. |
uint YieldUntil(uint lastTime, uint delay) | Fixed-period pause: sleeps until lastTime + delay, returns the new lastTime to pass back in next iteration. |
SetError(int) records an error code without halting the VM. The host application can read it after the script finishes. The last call wins. The default is 0.
A set of math functions is built into the language under the Math namespace. They are part of the VM itself, so they are always available, whatever natives the host provides.
| Function | Result |
|---|---|
Math::Sqrt(x) | Square root. |
Math::Pow(base, exp) | base raised to exp. |
Math::Sin(x), Math::Cos(x), Math::Tan(x) | Trigonometric functions. x is in radians. |
Math::Asin(x), Math::Acos(x), Math::Atan(x) | Inverse trigonometric functions, in radians. |
Math::Atan2(y, x) | Angle of the point (x, y) in radians, in the range -pi to pi. |
Math::Exp(x) | e raised to x. |
Math::Log(x) | Natural logarithm. |
Math::Log2(x), Math::Log10(x) | Base 2 and base 10 logarithms. |
Math::Floor(x), Math::Ceil(x) | Round down / up to a whole number. |
Math::Round(x) | Round to the nearest whole number, halves away from zero. |
Math::Fmod(x, y) | Floating point remainder of x / y. |
Math::Abs(x) | Absolute value. |
Math::Min(a, b), Math::Max(a, b) | Smaller / larger of the two. |
All functions take and return float. An int argument is converted to float first, the same as passing it to a float parameter.
Abs, Min and Max are the exception: when every argument is an integer type they work in integers and return int, so int m = Math::Max(3, 7); is exact with no float round trip. If any argument is a float, including a mixed expression like i + 0.5, the whole call is done in float.
A domain error such as Math::Sqrt(-1.0) or Math::Log(0.0) produces NaN or infinity, as in C. It does not halt the VM.
if, else, loop body, or switch cannot span more than 64 KB of bytecode (the compiler reports “Too much code to jump over”), and the VM’s data area (globals plus stack) is capped at 65,535 slots, which is 256 KB.try/catch/throw. A genuine runtime error halts the VM. Use SetError for recoverable conditions.Every run ends with a status. “End” means the script finished normally. Anything else is an error that stopped it. The common ones are:
| Error | Cause |
|---|---|
| Division By Zero | An integer or float division, or a modulus, by zero. |
| Array Index Out Of Bounds | A variable array index was outside the array. |
| Stack Overflow | The script ran out of stack, usually from deep recursion or large local arrays. |
| Native Function Not Resolved | The script called a native the host doesn’t provide. |
| Call Arg Count Error | The host called a callback with the wrong number of arguments. |
| Stack Underflow, Pointer Out Of Bounds, Unknown Instruction | A damaged binary, or a problem in the VM or host rather than in the script. |
A binary can also be refused when it’s loaded, before any of it runs: “Unsupported Version” for a binary compiled for a newer language version, and “Invalid Script” for one that is malformed or fails its checksum.
Output:
The TCM hosts a powerful in-house developed scripting language called EmC. This allows users to write their own functionality to do almost anything from advanced CAN integrations to special control functions for transmission or vehicle systems.
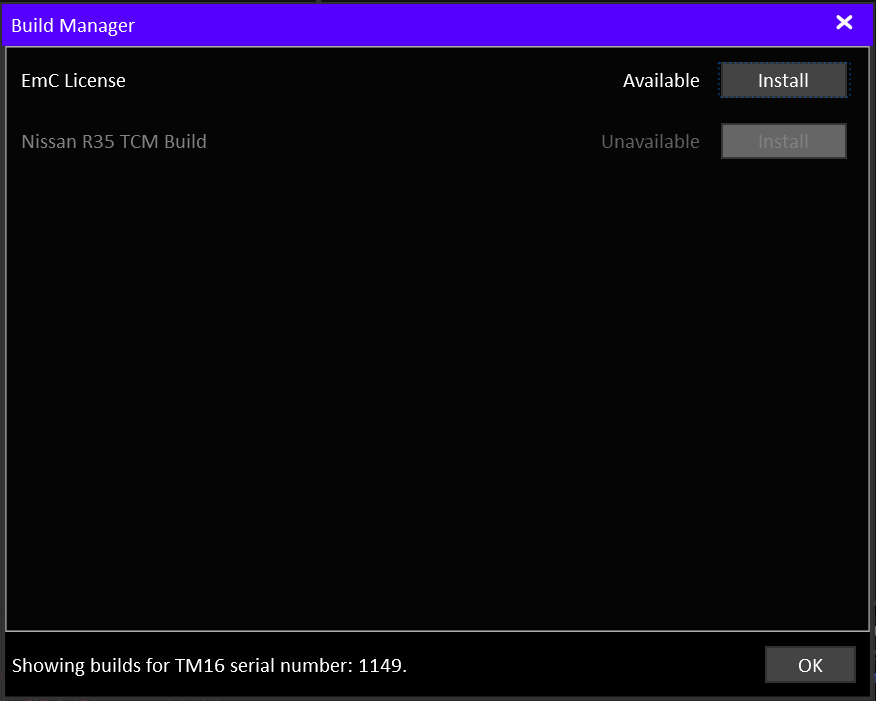
EmC requires a Developer License and must be activated using the Build Manager on each device.
EmC is a statically-typed, heap-less, C-style scripting language for 32-bit embedded systems.
Source files (.emc) compile to a compact bytecode binary (.emcbin) that runs on a stack-based virtual machine inside the host device.
EmC is compiled before it reaches the hardware, so developers can distribute their own proprietary compiled code without the user having or requiring access to the source code.
Once an EmC binary is uploaded to the device, it cannot read back and exported for redistribution without the original file.
Because EmC is statically typed, a lot of error checking is done at compile time, reducing the chance of runtime errors or undefined behavior.
See EmC language documentation for more detail.
Dealers with a current EmC Developer License can purchase and activate the EmC Application Build on a device.
Once EmC has been enabled for your device’s serial number, use the Build Manager to activate it.
The EmC development environment is accessed via the “EmC” tab when a cal file is open or a TCM is online. The environment can be opened without a device or cal file from the EmC menu.
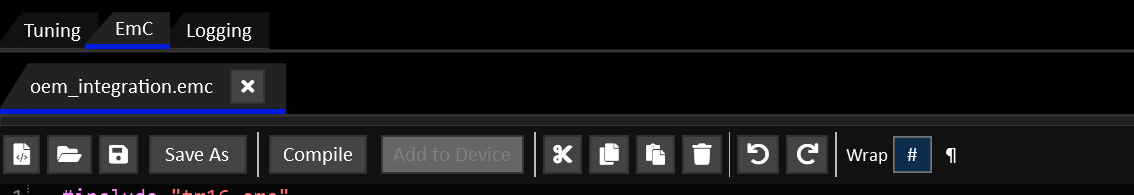
Press Compile on the toolbar to compile the script (along with any emc files it includes). The compiler result is shown on the RHS.
On a successful compilation, the script to be added to the device script management list by clicking Add to Device.
Errors shown in the compiler output will also he highlighted in red in the editor panel. Warnings shown in the compiler output will also he highlighted in yellow in the editor panel.
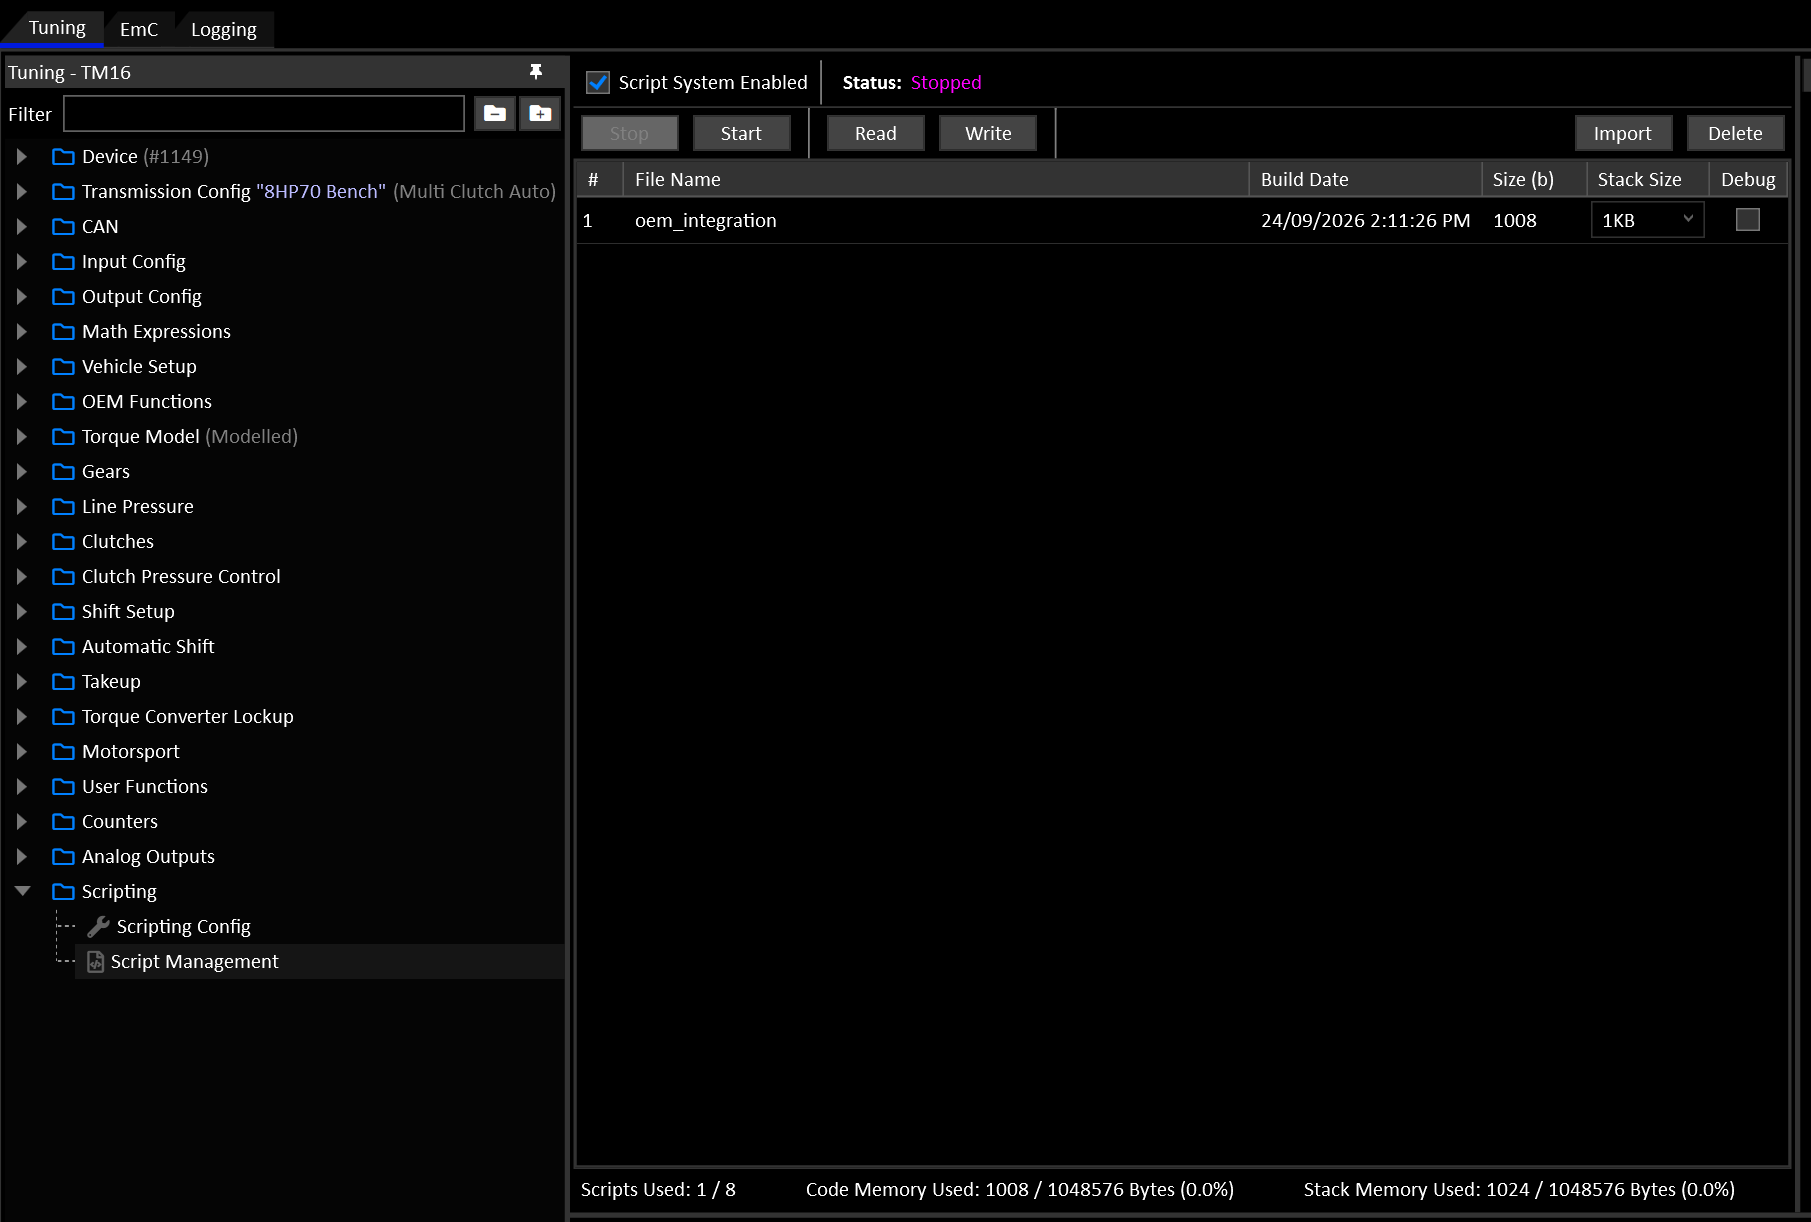
The Script Management view shows the scripts either in the device or staged for upload.
In order to upload changes to the script memory, the script system must be stopped.
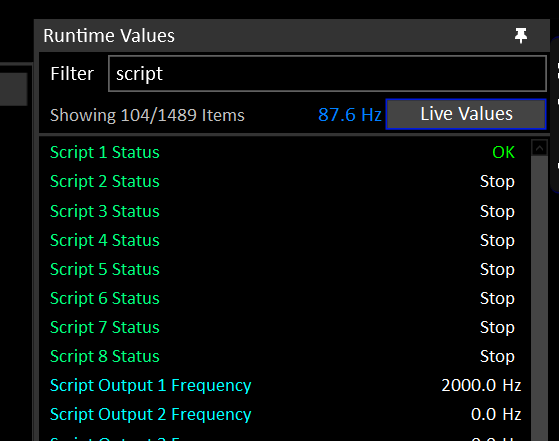
Stop halts the script system, ready to upload changes.Start starts a halted system and starts all scripts running.Read Reads the script memory from the device.Write sends the current script memory and configuration to the device and starts the system.Import imports a compiled EmC binary file (.emcbin). This can be used to import compiled 3rd party scripts without the source files.Delete removes the selected script file from the list.Each Script has it’s own status runtime. A successfully running script’s status will show “OK”.
This is a reference for every native function callable from a EmC script running on the TCM including:
System:: for debugging and time management.Runtime::, Torque::, Device::, CAN:: and Output:: for reading live device state, supplying engine torque, talking to the CAN bus and driving script-controlled outputs.System::)| Function | Signature | Purpose |
|---|---|---|
| System::Print | void Print(string str) | Debug-print a string, no newline |
| System::PrintLine | void PrintLine(string str) | Debug-print a string plus newline |
| System::PrintInt | void PrintInt(int i) | Debug-print an integer |
| System::PrintFloat | void PrintFloat(float f) | Debug-print a float |
| System::PrintFormat | void PrintFormat(string str, float f) | Debug-print a format string with one float |
| System::PrintBuffer | void PrintBuffer(byte buf[], int capacity) | Debug-print a byte buffer’s null-terminated content |
| System::StrLength | int StrLength(byte buf[], int capacity) | Length of a buffer’s content up to its null terminator |
| System::StrCopy | void StrCopy(byte dest[], int destCapacity, string src) | Copy a string constant into a buffer, truncating to fit |
| System::StrAppend | void StrAppend(byte dest[], int destCapacity, string src) | Append a string constant onto a buffer’s content, truncating to fit |
| System::IntToStr | void IntToStr(byte dest[], int destCapacity, int value) | Format an integer as decimal text into a buffer |
| System::StrEquals | bool StrEquals(byte a[], int capacityA, byte b[], int capacityB) | Compare two buffers’ null-terminated contents |
| Function | Signature | Purpose |
|---|---|---|
| System::NowMs | uint NowMs() | Device uptime in milliseconds (wraps every ~49.7 days) |
| System::NowUs | uint NowUs() | Device uptime in microseconds (wraps every ~71.58 min) |
| Function | Signature | Purpose |
|---|---|---|
| System::Yield | void Yield(uint t) | Pause the script for t milliseconds |
| System::YieldUntil | uint YieldUntil(uint lastTime, uint delay) | Fixed-period pause that returns the updated lastTime for the next call |
Runtime::)| Function | Signature | Purpose |
|---|---|---|
| Runtime::Read | int Read(uint id) | Read a live channel value as an integer with the decimal point removed (123.4 reads as 1234) |
| Runtime::ReadReal | float ReadReal(uint id) | Read a live channel value as a float in real units |
| Runtime::Write | bool Write(uint id, int value) | Write a writeable channel value as an integer with the decimal point removed |
| Runtime::WriteReal | bool WriteReal(uint id, float value) | Write a writeable channel value as a float in real units |
Torque::)| Function | Signature | Purpose |
|---|---|---|
| Torque::GetSupplied | float GetSupplied() | Read Engine Torque (Supplied) in Nm |
| Torque::SetSupplied | void SetSupplied(float tqSupplied) | Supply Engine Torque (Supplied) when Torque Model Source is Script |
| Torque::GetAvailable | float GetAvailable() | Read Engine Torque (Available) in Nm |
| Torque::SetAvailable | void SetAvailable(float tqAvailable) | Supply Engine Torque (Available) when Torque Model Source is Script |
| Torque::GetDriverDemand | float GetDriverDemand() | Read Driver Demand Torque in Nm |
| Torque::SetDriverDemand | void SetDriverDemand(float tqDriver) | Supply Driver Demand Torque when Driver Demand Source is Script |
CAN::)| Function | Signature | Purpose |
|---|---|---|
| CAN::SetupNode | bool SetupNode(uint node, bool enable, uint bitrateSelect, bool termination, bool listenOnly) | Enable/disable a CAN node and set its bitrate, termination and listen-only mode |
| CAN::Send | void Send(uint node, uint id, byte buffer[], int length) | Send a raw frame on CAN 1 or CAN 2 |
| CAN::Read | int Read(uint node, uint id, byte buffer[], int length) | Poll the latest received frame for a node/id pair |
| CAN::Subscribe | void Subscribe(uint node, uint idMatch, uint idMask, func(uint id, byte data[], int length) handler) | Register a callback for received frames matching an id/mask |
| CAN::Unsubscribe | void Unsubscribe(uint node, uint idMatch, uint idMask) | Cancel a subscription registered with the same node/match/mask |
| CAN::Poll | int Poll() | Fire the handlers for any frames received since the last call |
Output::)| Function | Signature | Purpose |
|---|---|---|
| Output::SetActiveLevel | void SetActiveLevel(byte outputId, int level) | Set a script output’s active polarity (0 = active-low, 1 = active-high) |
| Output::SetEffectiveResistance | void SetEffectiveResistance(byte outputId, float ohms) | Tell current control the load’s resistance |
| Output::SetFreq | void SetFreq(byte outputId, float frequency) | Set a script output’s PWM/current-chop frequency in Hz |
| Output::SetDuty | void SetDuty(byte outputId, float dutyCycle) | Drive a script output in PWM mode at a fixed duty (0-100) |
| Output::SetCurrent | void SetCurrent(byte outputId, float milliAmps) | Drive a script output in closed-loop current control |
Device::)| Function | Signature | Purpose |
|---|---|---|
| Device::ReadSerialNumber | uint ReadSerialNumber() | Read the device’s serial number |
| Device::ReadVendorKey | uint ReadVendorKey(int keyId) | Read one of two vendor keys (keyId 1 or 2), typically used to lock a script to a specific device |
Every native function is called through its namespace.
Calling a native bare (Yield(10);, Poll();) or through the wrong namespace (System::Runtime::Read(1);) fails to compile. Function names are case-sensitive and must match the names in this manual exactly.
A callback handler passed to CAN::Subscribe (a func-typed parameter) is the one exception: it’s a bare script function name, not called through any namespace - see CAN Receive Callbacks.
Runtime ids (the uint id arguments to the Runtime:: functions) are plain numbers assigned by the device’s .mdef. Rather than hard-coding them, #include "mtc.emc" and use the RT_ names it defines - see Include Files.
Every CAN:: function takes a node as its first argument, zero indexed: 0 is CAN 1 and 1 is CAN 2. CAN::Subscribe and CAN::Unsubscribe also accept 2 for both buses; everywhere else 2 is rejected. The include file provides CAN1, CAN2 and CAN_BOTH for these.
Device header file(s) ship along side the compiler, so a script can refer to channels, buses, bitrates, etc by name instead of by number. Include it at the top of the script:
The file name is the device’s name in lower case: tm16.emc for the TM16. The compiler already knows where the shipped headers live, so the plain file name works wherever the script itself is saved. Including the same file more than once (e.g. from two of your own include files) is harmless.
| Group | Names | Meaning |
|---|---|---|
| Constants | LOW, HIGH | 0 and 1, for Output::SetActiveLevel |
| CAN buses | CAN1, CAN2, CAN_BOTH | The node argument of the CAN:: functions (0, 1, 2) |
| CAN Bitrates | CAN_BITRATE_125K, CAN_BITRATE_250K, CAN_BITRATE_500K, CAN_BITRATE_1M, CAN_BITRATE_CUSTOM | The bitrateSelect argument of CAN::SetupNode |
| Runtime Channels | RT_ENGSPD, RT_GEAR, RT_BATTVOLTS, … | The Runtime ID of every channel, for the Runtime:: functions |
A runtime channel’s name is RT_ followed by its abbreviation in upper case (the “Engine Speed” channel becomes RT_ENGSPD). Each define carries the channel’s full label as a trailing comment, so the quickest way to find a channel is to open the header and search for the channel name.
You are free to define your own constants too.
The header only provides names - it doesn’t change what any function does. A channel that isn’t writeable still refuses Runtime::Write whether it’s addressed by RT_ name or by number.
#define is used in preference to const uint declarations because unused defines have no effect on the compiled output. If you create 100 variable declarations (const or not), you will add 100 variables to the compiled script binary, that must also take up space on the stack when running.
Print, PrintLine, PrintInt, PrintFloat, PrintFormat and PrintBuffer all write to the same destination: a debug message sent to a connected PC over the device’s Ethernet port, rate-limited so a busy loop can’t flood it. None of them do anything unless all of the following are true:
[IMPORTANT] Always disable debug when it’s no longer required.
str in Print/PrintLine/PrintFormat must be a string - a compile-time string constant, not a byte[] buffer. Use PrintBuffer for buffer content instead (see String Buffers).
Prints a string literal with no newline.
Prints a string literal followed by a newline. Use it for the last piece of a line built up from several Print/PrintInt calls. PrintLine("") prints just the newline.
Prints i as a single integer value.
Prints f as a decimal float (%f format).
Prints str as a printf-style format string with f as its one and only argument, so only a single %f-style specifier makes sense. Anything else in the string that consumes an argument is undefined, the same way a mismatched printf format is in C.
Prints buf’s contents up to its null terminator, or up to capacity bytes, whichever comes first.
See StringBuffers.
string constants are immutable and can’t be built or modified at runtime - for text a script assembles itself (formatting a value, building a label from CAN data, etc.) it needs a byte[] buffer instead, plus the five string natives that operate on it. All five are C snprintf-style: every one takes an explicit capacity and truncates rather than overflowing.
Two easy mistakes to make:
StrCopy/StrAppend’s source (src) is always a string constant, never another byte[] buffer. There’s no buffer-to-buffer append.byte[] buffer can never be passed where a string parameter is expected. A freshly declared buffer is zero-filled, so StrLength on one that’s never been written returns 0.Scans up to capacity bytes for a \0 and returns how many bytes precede it: 0 if buf starts with \0, capacity if no terminator is found.
Copies src into dest, truncating and null-terminating to fit within destCapacity.
Appends src onto dest’s existing null-terminated content, truncating and null-terminating to fit within destCapacity.
Formats value as decimal text into dest, truncating and null-terminating to fit within destCapacity.
Returns true if a and b’s null-terminated contents are identical, each scanned up to its own capacity.
NowMs/NowUs read the device’s uptime from the same free-running hardware timer, but with different wrap periods.
Write comparisons the wraparound-safe way (unsigned subtraction) rather than assuming now only ever increases:
(uint)(now - start) >= threshold)
Uptime in milliseconds. Wraps every ~49.7 days (2^32 milliseconds), which makes it the safer default for a script tracking longer-running state (e.g. time since ignition-on).
Uptime in microseconds. Wraps every ~71.58 minutes (2^32 microseconds).
Because the two clocks wrap at different points, NowMs() and NowUs() / 1000 only agree with each other for the first ~71.58 minutes after boot - once NowUs has wrapped, NowMs keeps counting while NowUs has reset near zero, so don’t rely on them staying numerically related.
Pauses the calling script for t milliseconds, letting other threads (and the rest of the script scheduler) run. This is the standard way to pace a script’s own loop instead of spinning:
A fixed-period yield: sleeps until lastTime + delay, then returns the new lastTime (lastTime + delay) for the caller to feed back in on the next iteration. Unlike Yield, which always sleeps for a fixed duration from now, this keeps a loop’s period accurate even if the loop body’s own work takes a variable amount of time each iteration:
The function takes and returns lastTime explicitly rather than updating it in place (EmC has no reference parameters) - always reassign the return value back onto the variable you pass in, or the period will drift.
Runtime channels are the live values used throughout the TCM (engine RPM, gear, clutch pressures, launch targets and so on). Each is identified by its Runtime ID, available by name as RT_... from the device’s include file.
See the Runtimes reference document for a list of all runtime channels, their #define names, factors, decimals etc.
Channels come in two flavours from a script’s point of view:
Read/Write work in the channel’s integer representation: the real value with its decimal point removed, so a channel displayed as 123.4 (one decimal place) reads as 1234, and writing 1234 sets it to 123.4. A channel with no decimal places reads and writes as-is.ReadReal/WriteReal work in floating point units (123.4) and are the simpler choice unless you specifically want integer maths. The TCM is equipped with an FPU so floating point operations are trivial.Reads of an ID that doesn’t resolve to anything return 0. Writes only succeed (return true) if the target channel is writeable. Lots of channels are computed outputs, not inputs, and will refuse the write.
Channels driven by Input Functions such as Engine Speed must have their input assignment set to Script or they cannot be written to.
Reads the channel as an integer with the decimal point removed. Returns 0 if id is unknown.
Reads the channel as a float in its real units. Returns 0 if id is unknown.
Writes value, an integer with the decimal point removed, to the channel. Returns true if the channel accepted the write, false if id is unknown or the channel is not writeable.
Writes value, a float in the channel’s real units.
Returns true if the channel accepted the write, false if id is unknown or the channel is not writeable.
A script can supply engine torque to the TCM, e.g. when the ECU sends torque in a format the CAN setup can’t decode directly, or when torque needs to be calculated from other channels. See TCM Torque Model for how the TCM uses these values.
Torque::SetSupplied and Torque::SetAvailable only take effect while Torque Model Source is set to Script.Torque::SetDriverDemand only takes effect while Driver Demand Source is set to Script.Values are in Nm. The torque correction and offset tables (when enabled) are applied on top of the value the script supplies: Engine Torque Correction and Engine Torque Offset for Supplied and Available, Driver Demand Torque Correction and Driver Demand Torque Offset for driver demand. The Get functions return the final value after correction and offset. A supplied value is held until the script sets a new one, so a script that stops or faults leaves the TCM using its last torque values.
Always set both Supplied and Available torque. If the ECU only provides one torque value, set it to both. If Engine Torque (Available) is left at 0, the TCM will think the engine has no torque available and request a full cut on every upshift.
The torque channels can’t be written with Runtime::Write or Runtime::WriteReal. Use the Torque:: functions instead.
Returns Engine Torque (Supplied) in Nm: the torque the engine is producing now, after any ignition retard or cuts. Works in every Torque Model Source mode.
Supplies Engine Torque (Supplied) in Nm. Ignored unless Torque Model Source is Script.
Returns Engine Torque (Available) in Nm: the torque the engine would be producing with no retard or cuts. Works in every Torque Model Source mode.
Supplies Engine Torque (Available) in Nm. Ignored unless Torque Model Source is Script.
Returns Driver Demand Torque in Nm. Works in every Driver Demand Source mode.
Supplies Driver Demand Torque in Nm. Ignored unless Driver Demand Source is Script.
Every CAN:: function takes a node as its first argument (0 indexed):
0 = CAN 1,1 = CAN 2Subscribe/Unsubscribe also accept 2 = both buses.Configures and restarts a CAN node from the script, replacing the node’s settings from the calibration.
Returns true on success, false if node is not 0 or 1.
enable - false turns the node off entirely (no transmit, no receive, termination off). The other arguments are still stored but have no effect until the node is enabled again.bitrateSelect0 = Custom bit timing1 = 125 kbit/s2 = 250 kbit/s3 = 500 kbit/s4 = 1 Mbit/stermination - switches the node’s on-board 120R termination resistor on or off.listenOnly - true puts the node in silent mode: it receives frames but never transmits or acknowledges, and the node’s configured CAN transmit channels are stopped. Use it to read from a bus the TCM must not disturb.Calling it restarts the node, so any frames in flight on that bus are lost. Call it once at script start, NOT from inside the loop. The new settings are not saved to flash by the call itself, so a script that depends on them should apply them every time it starts.
Send/Read are the simple, polling pair. Both target one bus, so node must be 0 or 1. 2 is rejected (Send does nothing, Read returns -1).
Queues a CAN message with identifier id and the first length bytes of buffer (at most 8) for transmission on node. The call returns as soon as the frame is queued; it does nothing if node is not 0 or 1 or length is 0.
Copies the most recently received frame with identifier id on node into buffer, up to length bytes, and returns the number of bytes copied. Returns -1 if no frame with that id has been seen on that bus yet.
The device keeps the latest frame for each node/id pair a script has asked about, and each Read call copies out of that store, so reading a frame doesn’t consume it: the same frame is returned again until a newer one arrives. The system holds a fixed number of node/id pairs (16, shared across all running scripts); once it’s full, Read on a pair it isn’t already tracking returns -1. This is fine for a handful of ids a script cares about. If you need every frame on a range of ids, or lower latency, use the callback API below instead.
CAN::Subscribe registers a script function to be called for every received frame whose id matches an id/mask pair, on CAN 1, CAN 2 or both. One subscription can cover many ids (see Id/Mask Matching). Handlers don’t run the instant a frame arrives: matching frames are queued for the script, and CAN::Poll() - called from the script’s own loop - runs each handler in turn on the script’s own thread. This means a callback can never delay real CAN traffic, but also means it only ever fires when the script calls CAN::Poll().
Subscribes a handler to a range of CAN messages:
node - 0 = CAN 1, 1 = CAN 2, 2 = both (CAN1, CAN2, CAN_BOTH from the include file).idMatch/idMask - a frame matches when (frame.id & idMask) == (idMatch & idMask). A mask of 0 matches every id on the node.handler - a bare script function name (no parentheses, no namespace), which must be declared with exactly this signature:id is the received frame’s identifier, data holds its payload and length is how many of those bytes are valid (0-8). A handler with the wrong parameter count or types is rejected at compile time.
data is only valid until the handler returns. Index it, or pass it straight on to another function that takes a byte array (such as CAN::Send), but copy it into a script-declared array if you need the bytes afterwards. Each frame delivered to a handler also uses a little extra script stack on top of the handler’s own locals, so a script running very close to its stack limit can halt with a stack-overflow fault on delivery rather than silently missing the callback.
Calling Subscribe again with the same node/idMatch/idMask replaces the existing subscription’s handler rather than adding a second one.
Removes a subscription. Pass the exact same three values it was registered with.
Runs the handlers for every matching frame received since the last call, oldest first, and returns how many handlers were fired. A subscribing script must call it once per loop iteration, before yielding, or queued frames simply sit until the next call.
The queue holds a fixed number of frames per script. If a script falls behind a busy bus (e.g. it’s blocked doing other work), the oldest undelivered frames are dropped rather than the queue growing. Keep the loop tight and call Poll() regularly if you’re subscribing to high frequency message(s) or a wide mask. Calling Poll() from inside a handler (directly or indirectly) does nothing and returns 0.
The match is a bitwise AND against both sides, not a range check:
idMask are the ones that must match.idMask are don’t-care and match any value.A few common patterns:
The frame’s actual ID is always passed to the handler as its first argument, so a single wide-mask subscription can still tell which specific id triggered each call:
Script outputs are a dedicated pool of up to 24 output channels that can be used to drive solenoids etc.outputId ranges from 1-24, not 0-based. ID 0 or anything above 24 resolves to nothing and does nothing.
Each output has to be assigned to a physical pin in the device’s configuration before a script can usefully drive it. An unassigned output accepts every call here without error but has no effect on hardware.
The script has no way of knowing which physical output the user assigned to a given Script Output.
Eg: Script Output 1, with ID 1, maybe be assigned to drive Solenoid Output 7 (or any other output pin by the end user).
SetDuty and SetCurrent set the output’s drive mode. Calling one switches the output into that mode and zeroes the other’s setpoint, so the two are mutually exclusive per output.
Whichever was called most recently wins.SetFreq applies to both modes.
Sets whether the output is driven active-high (1) or active-low (0).
LOW and HIGH definitions are in the device include file.
Auxiliary Outputs Only
Tells the current control system the resistance of the connected load. Used to help translate the current target into a drive duty. Only relevant in current-control mode when the output is assigned to an auxiliary output rather than a solenoid output.
If the output’s effective resistance is set to 0 (Recommended and default), the system will work it out on it’s own. The only drawback is that the first application of the solenoid may take a few extra milliseconds to settle on the current target.
Where possible, preference using the solenoid outputs, not auxiliary outputs to drive current-controlled loads.
Sets the output’s switching frequency in Hz:
PWM Range: 0.5 - 20000 Hz
Current Control Range: See below
When an output is in current control mode, it’s frequency must be one of the following options:
In PWM mode, any frequency up to 20000 Hz (20 KHz) is fine.
Once the duty cycle has been set, putting the output into fixed PWM mode, the frequency can be changed at will, even without updating the duty cycle again. This makes it possible to do variable frequency outputs such as a tacho output.
Puts the output in fixed-duty PWM mode at dutyCycle percent (0-100) and clears any current target.
Puts the output in closed-loop current-control mode with a target of milliAmps and clears any duty setpoint.
Output Current Range
Solenoid Outputs are the preferred output for current controlled loads.
A common use is locking a script to a specific device or vendor: compare the serial number and/or a vendor key that only the vendor knows and gives to the user, against an expected value at script start and refuse to run if it doesn’t match.
Returns the device’s serial number.
Returns one of two general-purpose 32-bit calibration values (“Script Vendor Hardware Key 1/2”), set like any other calibration value. keyId is 1 or 2; any other value returns 0.
The Script Vendor Hardware Key # variables are kept at the device level. This means that uploading a cal file with different values in the keys, will not change the values in the device. They will be ignored from the cal file data. This stops the sharing of cal files that run the same scripts from breaking script execution when uploaded.